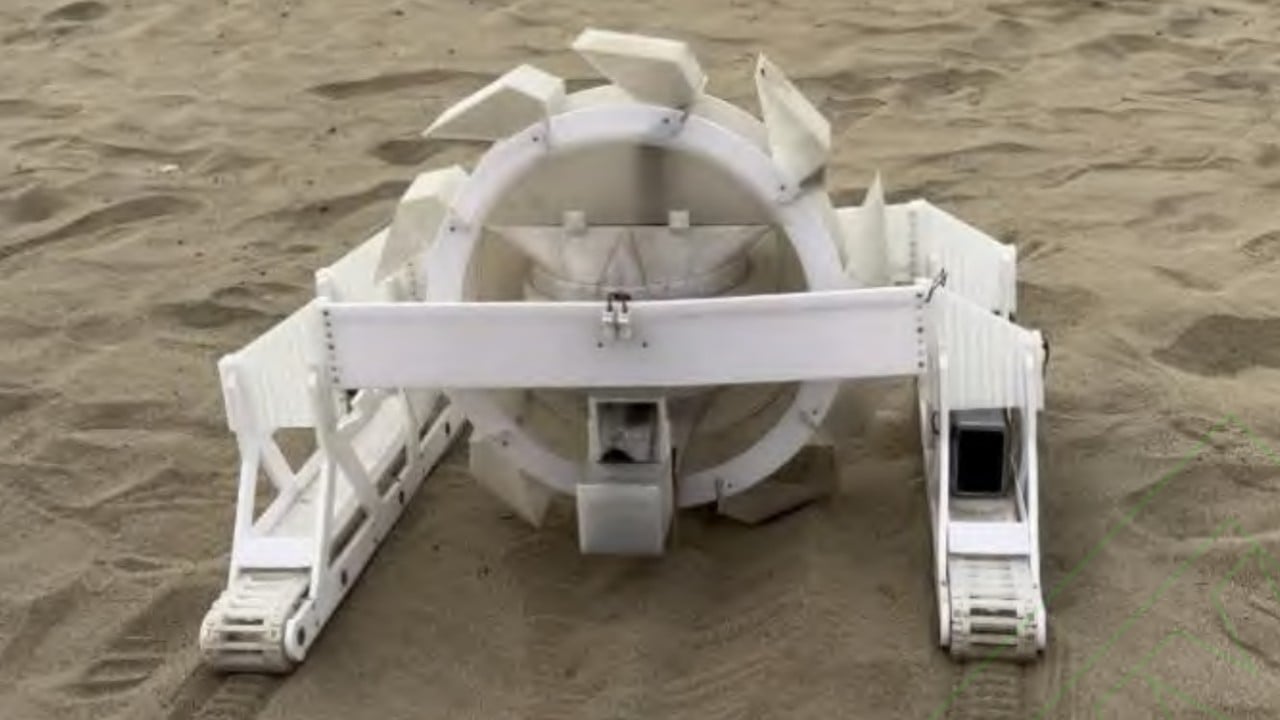
Science fiction loves a good desert planet. Now, real life is catching up to cinema. Deep inside the shifting dunes of China's Taklamakan Desert, engineers are testing specialized crawler robots designed to harvest iron directly from raw sand.
If you picture a clumsy machine sinking into loose dunes, you don't understand modern robotics. These crawler units use specialized magnetic systems and adaptive treads to traverse extreme terrain without getting swallowed by the shifting sands. They operate in one of the most hostile environments on Earth. Temperatures swing wildly, windstorms reshape the geography overnight, and water is virtually nonexistent. Yet, these machines keep moving. Learn more on a connected subject: this related article.
Why the Taklamakan Desert Matters for Robotics
The Taklamakan isn't just a vast expanse of empty sand. It covers roughly 337,000 square kilometers in China's Xinjiang region, making it one of the largest shifting-sand deserts on the planet. For decades, traditional mining companies ignored regions like this. The logistical nightmare of moving heavy equipment across hundreds of kilometers of loose dunes made resource extraction economically unviable.
Manual labor is impossible here on a large scale. Traditional heavy trucks bog down immediately. Tracked vehicles suffer from intense mechanical wear as abrasive quartz sand strips gears and clogs engines. Engineers had to rethink mobility from scratch. More journalism by The Verge highlights related perspectives on the subject.
The new breed of crawler robots solves this through distributed weight distribution and rare-earth magnetic separation arrays. Instead of digging massive pits and hauling millions of tons of earth to a processing plant, these units process the surface material on the fly. They separate iron-rich minerals from the surrounding quartz sand directly on location, leaving the sterile tailings behind.
The Engineering Behind the Sand Crawlers
Building a robot that survives a hyper-arid desert requires solving three distinct problems: thermal management, mobility, and power autonomy.
Standard electronics fry when ambient surface temperatures push past 50 degrees Celsius. Internal cooling loops must reject heat without drawing in fine dust that acts like sandpaper on moving parts. The crawlers use sealed chassis designs with magnetic fluid seals to keep the interior pristine.
Mobility relies on wide, low-ground-pressure treads that distribute weight evenly. Think of how snowshoes prevent a hiker from sinking into deep powder. These treads use similar physics, scaled up for industrial payloads. As the crawler moves across a dune, magnetic rollers sweep through the top layer of sand, capturing micro-particles of iron oxide before the wind can scatter them further.
[Surface Sand] ---> [Magnetic Collection Array] ---> [Iron Separation] ---> [Clean Tailings Dropped]
This decentralized approach means you don't need a massive central refinery sitting in the middle of an ecological sensitive zone. You deploy a swarm of autonomous units. If one breaks down, the operation continues without missing a beat.
Economic and Environmental Realities
Skeptics wonder if extracting iron from desert sand will ever scale economically compared to traditional open-pit mining in Australia or Brazil. Traditional mines pull massive, high-grade ore bodies straight out of the ground. Desert sand contains a much lower concentration of usable minerals per ton.
The economics change when you factor in infrastructure costs. Building slurry pipelines and heavy rail lines across shifting dunes costs billions of dollars and decades of environmental approvals. Autonomous crawlers require zero permanent roads. They can be shipped in standard containers, unloaded at the edge of the desert, and driven directly into the field under remote supervision.
Environmental impact is another critical factor. Traditional mining destroys local habitats and leaves massive scars on the landscape. Small-footprint robotic harvesters leave the surrounding dune topography largely intact. They skim the surface layers where wind action constantly replenishes the mineral content through natural erosion from surrounding mountain ranges like the Kunlun and Tianshan systems.
What Comes Next for Autonomous Resource Gathering
We are watching a fundamental shift in how heavy industry approaches extreme geography. Once you prove that autonomous crawlers can extract minerals from the Taklamakan, the same technology applies to other harsh environments. Think of remote Arctic tundra, high-altitude plateaus, or even off-world exploration where human presence is too risky or expensive.
The technology isn't flawless yet. Battery degradation in extreme heat remains a hurdle, and long-term autonomous navigation during severe sandstorms still requires human oversight. But the prototypes are already working in the field.
Stop viewing deserts as dead zones. Industry leaders now see them as vast, untapped processing floors.
Watch How China Tames The Deadly Desert to see how large-scale engineering projects are transforming the harsh landscape of the Taklamakan Desert.